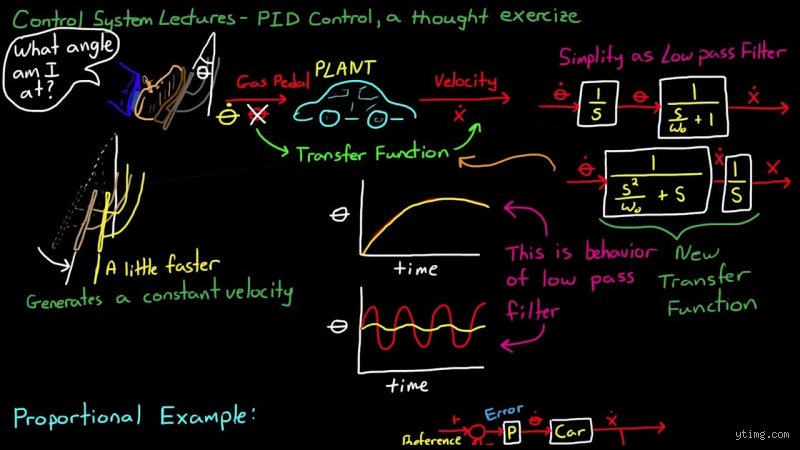
Understanding the mechanics behind Proportional integral derivative Control
Control theory used to live only in dusty academic texts from the 1930s. Yet today, it dictates how a chemical plant in Houston handles a 150-degree exothermic reaction without blowing the roof off. The complication is balancing reaction speed against system stability. Because if you push a process variable too hard, oscillation takes over instantly. (And trust me, tuning a stubborn loop at 3 AM makes you question your life choices.)
The Proportional gain component and error magnitude
Proportional action acts like a startled reflex. When the measured process variable drifts away from the setpoint, this term immediately outputs a correction scaled directly to the current error. If your target temperature is 100 degrees Celsius and you sit at 90, the P-term multiplies that difference by a constant multiplier known as gain. But relying solely on proportional control leaves a permanent offset behind. The system settles close to the target, yet never quite reaches zero error. Specialists don't agree on whether pure P-control still has modern utility, but honestly, it causes endless steady-state headaches in high-precision setups.
The integral term and past error accumulation
Integral action fixes that lingering offset by looking backward. It scoops up every past error over a timeline measured in seconds or milliseconds, accumulating them until the output forces the process variable precisely onto the target line. Imagine driving up a steep hill in a 2022 Ford F-150; the engine needs extra throttle that accumulates the longer the slope fights your momentum. Yet, if you crank the integral gain too high, overshoot happens violently. The system swings past the target, overcompensates, and oscillates wildly like a pendulum on caffeine.
Advanced industrial applications in modern manufacturing plants
Moving past textbook theories, let us look at real hardware operating right now. In a massive semiconductor fabrication plant in Dresden built back in 2021, precise gas flow controllers rely on digital PID algorithms executing at a blistering 1000 Hertz update rate. These loops manage corrosive silane gas pressures down to 0.001 PSI tolerances. We're far from simple mechanical linkages here. The trouble is that sensor noise can corrupt the derivative term entirely, turning tiny electrical spikes into massive actuator jolts.
Derivative action and anticipating future trajectories
Derivative action acts as the crystal ball of the trio. Instead of staring at present mistakes or past baggage, it calculates the rate of change. If the error shrinks rapidly, the D-term applies a braking force to prevent overshooting the target. Think of a cruise control system on a 2024 Tesla Model Y detecting a downward slope; it eases off the accelerator before gravity accelerates the vehicle past the speed limit. Still, real-world sensor noise creates high-frequency jitter, forcing engineers to insert low-pass filters just to keep derivative calculations from burning out control valves.
Cascade Control loops in chemical processing units
Sometimes a single loop cannot handle complex dynamics. Enter cascade control, where a master controller dictates the setpoint of a slave loop. In a crude oil distillation column operating at ExxonMobil's Baytown refinery, a primary temperature loop feeds a secondary fuel gas flow loop. This nested architecture isolates disturbances before they ruin the entire distillation batch. Process variable filtering and anti-windup mechanisms prevent the internal math from locking up during extreme operational saturations.
Comparing PID architecture with modern advanced Control strategies
Traditional loops have rivals nipping at their heels. Model Predictive Control has taken over massive oil refineries and complex robotics because it forecasts future behavior using mathematical plant models instead of just reacting blindly. Yet, tuning an MPC requires heavy computational muscle and expensive software licenses. Meanwhile, a standard PID block runs smoothly on a cheap Microchip microcontroller costing less than two dollars. That's why PID refuses to die, even in an era dominated by machine learning.
Fuzzy logic integration and neural network tuning hybrids
Adaptive tuning rules try to bridge the gap between old-school feedback and modern AI. By pairing traditional loops with fuzzy logic rule sets, control engineers handle non-linear processes that baffle standard linear formulas. A robotic arm manufactured by FANUC in Japan uses fuzzy gain scheduling to adjust its PID parameters dynamically as the payload weight shifts from zero to fifty kilograms. The system adapts on the fly, proving that old mathematical foundations can wear smart new outfits without breaking a sweat.
Common mistakes
Tuning by pure guesswork
Many technicians treat a proportional-integral-derivative controller like a mysterious black box, turning random knobs until the motor stops shaking. But this trial-and-error method usually leads to aggressive overshoot or sluggish recovery times. Guessing parameters wastes hours of valuable production life. A proper calibration requires method, patience, and a firm grasp of the process dynamics. As a result, engineers frequently burn out trying to tame erratic machinery without any systematic tuning protocol.
Ignoring sensor noise
Bad measurements ruin feedback loops. Raw sensor data arrives packed with high-frequency static that tricks the derivative term into overreacting. But you can fix this by introducing a low-pass filter to smooth the incoming signal before it hits the error calculation. The trouble is that operators often crank up the D-gain without checking filter settings, which heats up actuators and wears out mechanical joints prematurely. (Irony is watching a high-end robotic arm destroy its own gears because nobody bothered to filter out a tiny electrical buzz.)
Treating every system the same
A formula that stabilizes a chemical reactor will utterly fail on a high-speed quadcopter. Every physical domain possesses unique inertia and delay characteristics. That's why copy-pasting tuning values across different PID examples causes catastrophic instability. We must respect the physical constraints of the plant instead of pretending software alone can fix bad hardware design.
What most people miss
Anti-windup safeguards
When an actuator hits its physical limit, the integral term keeps accumulating error behind the scenes, creating a massive overshoot monster known as windup. Integral windup plagues inexperienced programmers who forget to clamp the accumulator. Because saturation halts physical progress while math marches on, the system suffers delayed recovery once the constraint lifts. Expert engineers implement conditional integration or back-calculation algorithms to freeze the accumulator whenever the output maxes out. This hidden technique saves millions of industrial valves from violent slamming every single day.
Frequently asked questions
How often should a digital controller sample the error?
Sampling frequency dictates how smoothly the system reacts to sudden disturbances. In modern industrial automation, a sampling rate of at least 10 to 20 times the bandwidth of the controlled process is standard practice. For instance, a high-speed disk drive servo loop might sample at 10 kilohertz to maintain nanometer-level precision. If you sample too slowly, the loop loses stability because it reacts to outdated states. In short, match your clock speed to the physical speed of the plant.
Can machine learning completely replace traditional control loops?
While neural networks and reinforcement learning capture massive attention, traditional feedback mathematics still dominate mission-critical applications. Over 90 percent of industrial control loops rely on standard PID algorithms because they require minimal computing power and remain completely transparent. Reinforcement learning models demand massive training data and can behave unpredictably when faced with edge cases. Therefore, AI works best as an adaptive supervisory layer rather than a direct replacement for deterministic feedback calculations.
Why does derivative action cause so much trouble in practice?
Derivative gain calculates the rate of change, making it hyper-sensitive to any sudden spike in the measurement signal. Even a minor 1 percent noise fluctuation can generate massive spikes at the controller output. This erratic behavior forces valves to chatter and motors to overheat during normal operation. Expert tuners often dial the D-term down to zero in noisy environments, relying solely on proportional and integral control to get the job done.
Where this leaves you
The obsession with tuning perfection misses the broader truth about modern automation. A control loop is only as good as the physical sensors feeding it and the mechanical actuators executing its commands. We spend too much time arguing over complex mathematical tweaks while ignoring messy real-world constraints like backlash, friction, and electrical noise. The future belongs to those who view control engineering as a holistic physical discipline rather than a pure software exercise. Let's stop treating feedback loops like magic and start designing hardware that actually respects the math.